
Control-link jammingis changing the battlefield.
10,000
drones a month lost by Ukraine, mostly to electronic warfare.
RUSI, Meatgrinder, 19 May 2023
Control linkConnected
GPSFix
Remote commandsAccepted
The commander writes the list.The aircraft picks from it.
LinkGPS
Staged render · not live telemetry
- ○Continue the mission
- ○Continue on visual and inertial navigation
- ○Climb to re-establish the link
- ○Loiter
- ○Return to base on the planned route
- ○Return to base on the alternate routeChosen
- ○Land at a safe site
Others sell autonomy that keeps flying when jammed.This is autonomy a commander bounds before flight and audits after.
| Capability | Ours | Terminal lock | Failsafe |
|---|---|---|---|
| Keeps the mission after the link drops | ✓ | ✓ Final approach only | ✕ Hover, return or land |
| Commander sets what it may do, before flight | ✓ Pre-authorized actions | ✕ Operator locks on in flight | – |
| Can only choose approved actions | ✓ Checked in code | – | – |
| Every decision recorded for review | ✓ Full decision record | – | ✕ |
| Runs on the aircraft's own computer | ✓ No cloud, no link | ✓ | ✓ |
| Works across makers' aircraft | Planned MAVLink autopilots | – | ✓ |
No link. No data center.The decision happens on the aircraft.
BEFORE FLIGHTCOMMANDER APPROVES
- Area modelMap and imagery of the operating area
- Pre-authorized actionsThe only moves the aircraft may make
- LimitsEnergy, area, hold time, authorization window
IN FLIGHTONBOARD · NO LINK
- 01LocalizeOursCamera against the area model
- 02DetectOff the shelfOff-the-shelf detectors
- 03MaskOursDrops actions outside the limits
- 04ChooseOursOne pass over what is left
- 05CheckOursRuntime assurance: monitor and fallback
- 06ActAutopilotThe autopilot's existing modes
Fallback chainIf the check fails: the next safe action, down to land at a safe site
RecordEvery decision, for the after-action review
Built in simulation.Run against the real autopilot.
- BuiltDecision engine and action filterChooses only from the approved set
- BuiltRun in ArduPilot software-in-the-loopThe real autopilot, simulated aircraft
- BuiltSigned aircraft-to-aircraft meshOptional; the mission runs without it
- BuiltVehicle detection on rendered imageryPretrained off-the-shelf detector
- NextMeasured on the reference computerNVIDIA Jetson Orin NX
- LaterFlight trialsUS range
PROVEN
- ArduPilot
- MAVLink
- PX4
- ROS 2
- Cursor-on-Target
- Now
- Unmanned aircraft
- Next
- Ground robots, surface and undersea vessels
Bounded before flight.Auditable after.
- 01Control link lost · GPS no fix
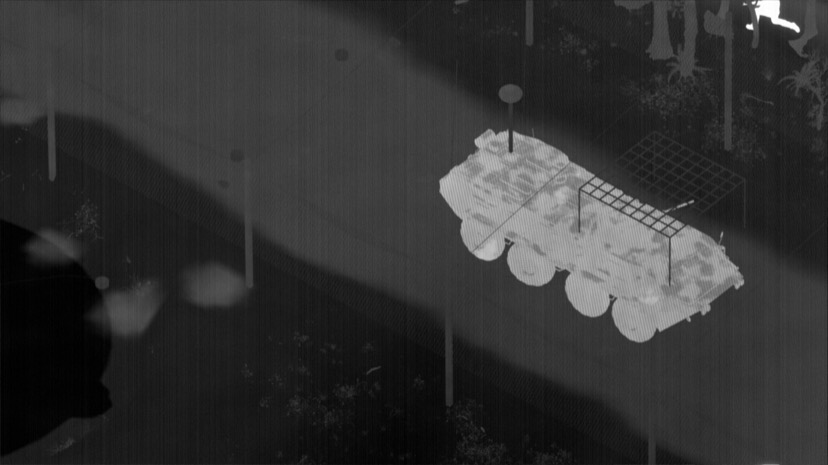
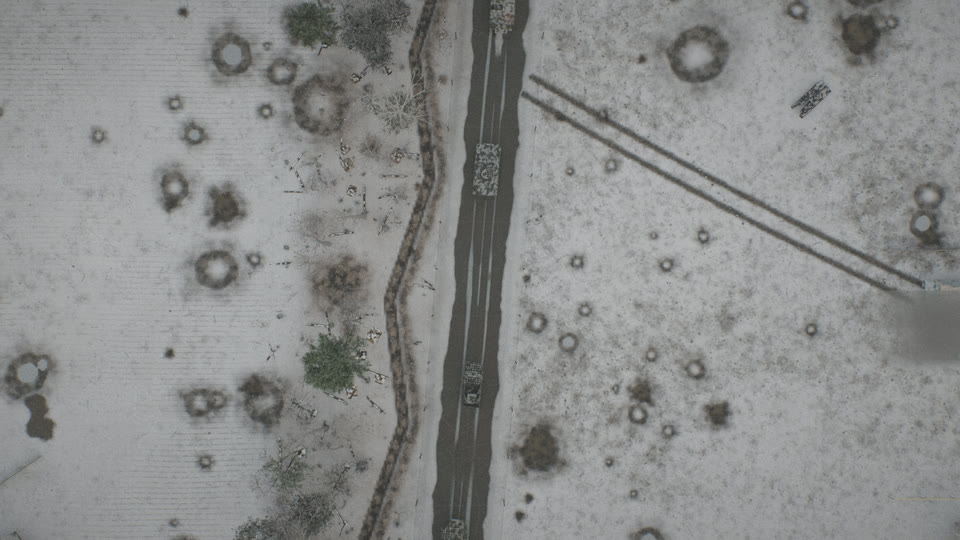
- 02Position from camera · road, wood edge, power line
- 03Detected · 2 vehicles near the landing site
- 04Limits applied · 7 pre-authorized actions
- 05✕ Continue the missionenergy reserve
- 06✕ Visual and inertial navigationenergy reserve
- 07✕ Climb to re-establish the linkhold cap
- 08✕ Loiterhold cap
- 09✕ Planned route homeinside jammer range
- 10✕ Land at a safe sitevehicles near site
- 11✓ Alternate route homechosen
- 12Output check passed · handed to the autopilot
- 01Engagement limits in codeArea, time window, no-strike list; commanders can only narrow them
- 02Decision recordEvery choice, its inputs and what was struck out, for after-action review
- 03DoD Directive 3000.09Records built to serve as evidence in autonomous-weapon review
- 04Export controlITAR / EAR classification; no technical data to foreign persons until licensed
- 05Captured aircraftWeights encrypted at rest; the approved set bounds the damage
Every flight is recorded.Every release is re-tested against the record.
- Revenue
- Recurring subscription for model updates
- First sale
- Terminal engagement after the link is cut
- Buyers
- Program offices; drone makers as integrators
- Funding routes
- SBIR, Defense Innovation Unit, AFWERX, other transaction agreements
- Markets
- United States first; allies and Ukraine after the export license
- Expansion
- The full mission after link loss, then every unmanned machine
Get in touch.
TEAM
- Jack MazacFounder · engineeringBuilt the decision engine, simulator and mesh
- Ben LindenbaumDefense and governmentFormer Pallas Advisors fellow, defense-tech strategy
- OttoMarketMarket and manufacturer relationships